Sarvesh Patil
PhD in Robotics @The Robotics Institute, CMU

Hello, welcome to my half quirky, half stereotypical academic website! I’m a PhD student in Robotics advised by Prof. Max Simchowitz. Prior to that, for my 1st 2 years of PhD and MS in Robotics at CMU, I was advised by Prof. Oliver Kroemer and Prof. Zeynep Temel.
As a PhD student I’m trying to understand the principles behind reinforcement learning, variational inference, and representation learning and how each can be effectively applied to learn highly specialized fine-grained & dexterous manipulation skills across a wide range of application domains. My recent work, OGPO, studies sample-efficient full-policy finetuning of generative control policies.
Previously, as a Master’s student, I developed an array of 64 soft delta robots in an 8×8 grid to push the limits of dexterous manipulation with non-anthropomorphic soft robots. For the 1st 2 years of my PhD, I developed a sample-efficient multi-agent behavior cloning and reinforcement learning pipeline with zero-shot sim2real deployment for planar object manipulation using the soft delta robot array.
Prior to joining CMU I used to work in HyperWorks Imaging, a small startup in Bangalore, where I worked on making Pix2Pix, Enhanced Super Resolution GANs, and vision-based inference pipelines to save a few million dollars for Sila Nanotechnologies developing carbon-based high energy density batteries. Before that, I did my Bachelors in Engineering in Electronics and Telecommunication in VES Institute of Technology (Mumbai University) on a Tuition Fee Waiver Scheme scholarship.
Please feel free to connect with me if you’re interested in learning actually dexterous manipulation policies, highly sample-efficient reinforcement learning, representation learning for cross task and cross embodiment transfer of learned skills.
Recently
| Jul 5, 2026 | Presenting OGPO: Sample Efficient Full-Finetuning of Generative Control Policies at ICML 2026! ✈️📍Seoul, S. Korea 🇰🇷 |
|---|---|
| May 22, 2026 | Started my summer internship at Toyota Research Institute (TRI)🤖! 📍Boston, MA |
| Sep 2, 2025 | Switched Labs! Started working with Prof. Max Simchowitz! 📍Pittsburgh, PA |
| May 19, 2025 | Started Summer Internship at Bosch Center for AI🤖! 📍Pittsburgh, PA |
| Aug 15, 2024 | Co-taught a group of 25 high school students basics of building robots and writing controllers for the Feiyue Summer School Program @CMU 🤖! 📍Pittsburgh, PA |
| Nov 6, 2023 | Organizing a workshop on Learning for Soft Robots at CoRL 2023 ✈️ 📍Atlanta, GA |
| Oct 1, 2023 | Helped organize my 1st workshop on Causality in Robotics at IROS 2023 ✈️ 📍Detroit, MI |
Selected research
All publications-
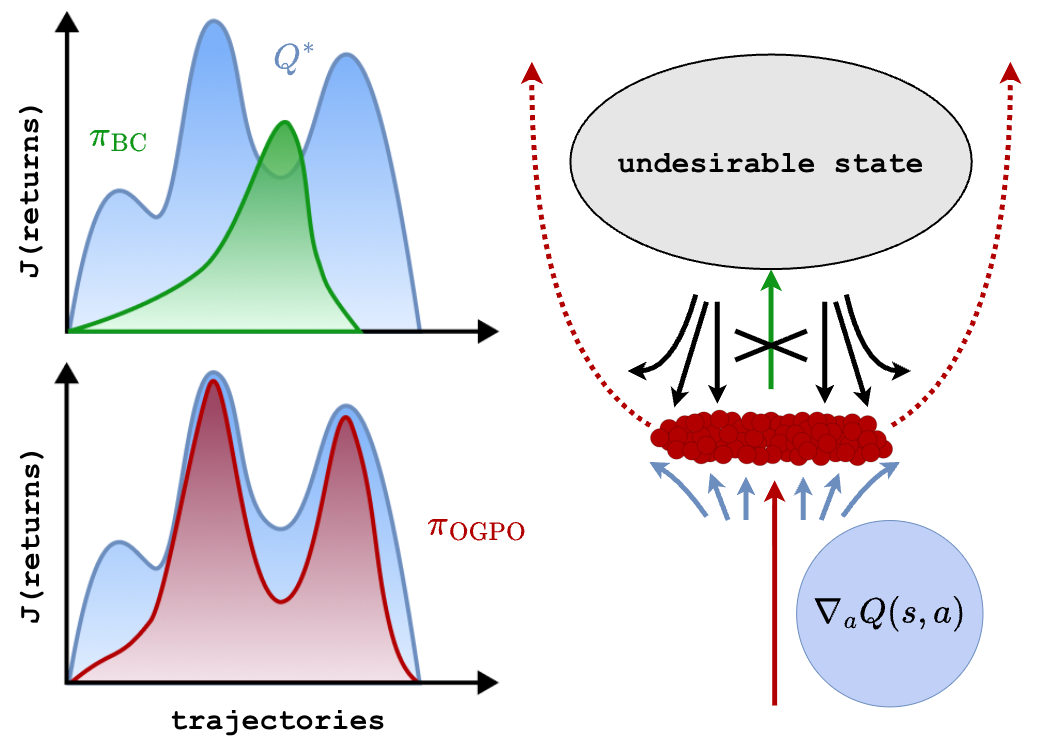 In International Conference on Machine Learning (ICML), 2026
Cite this paper
@inproceedings{patil2026ogpo, title = {OGPO: Sample Efficient Full-Finetuning of Generative Control Policies}, author = {Patil, Sarvesh and Nakamoto, Mitsuhiko and Agarwal, Manan and Saxena, Shashwat and Zhang, Jesse and Anantharaman, Giri and Winston, Cleah and Pan, Chaoyi and Chen, Douglas and Huang, Nai-Chieh and Temel, Zeynep and Kroemer, Oliver and Levine, Sergey and Gupta, Abhishek and Dai, Hongkai and Shah, Paarth and Simchowitz, Max}, booktitle = {International Conference on Machine Learning (ICML)}, year = {2026}, } -
 arXiv preprint arXiv:2609.06930, 2026
Cite this paper
@article{Patil2025MADDM, title = {Distributed Dexterous Manipulation with Spatially Conditioned Multi-Agent Transformers}, author = {Patil, Sarvesh}, journal = {arXiv preprint arXiv:2609.06930}, year = {2026}, } -
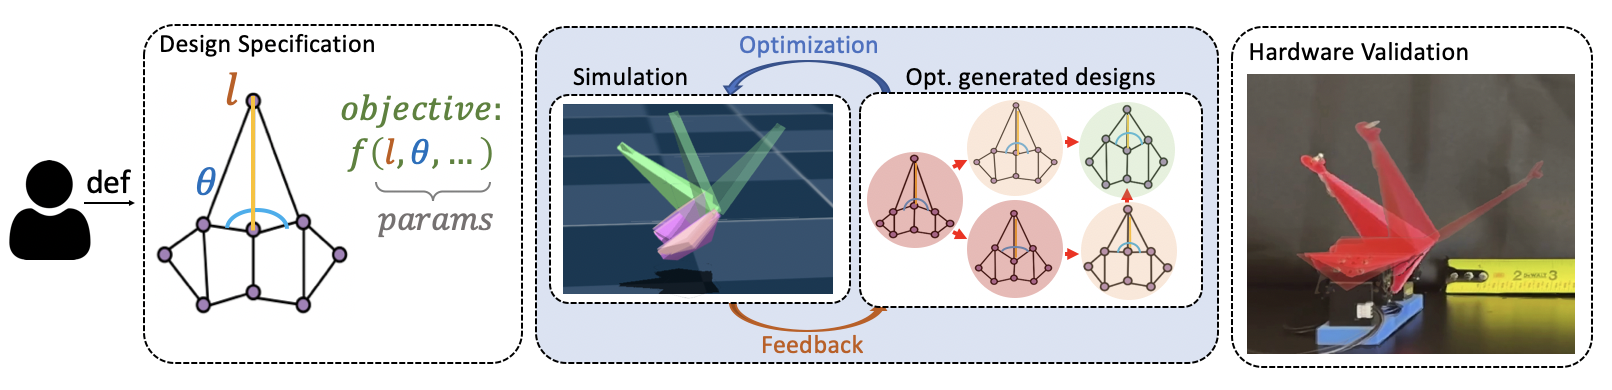 In IEEE International Conference on Soft Robotics (RoboSoft), 2026
Cite this paper
@inproceedings{han2026fold, title = {From Fold to Function: Simulation-Driven Design of Origami Mechanisms}, author = {Han, Tianhui and Singh, Shashwat and Patil, Sarvesh and Temel, Zeynep}, booktitle = {IEEE International Conference on Soft Robotics (RoboSoft)}, pages = {843--850}, year = {2026}, } -
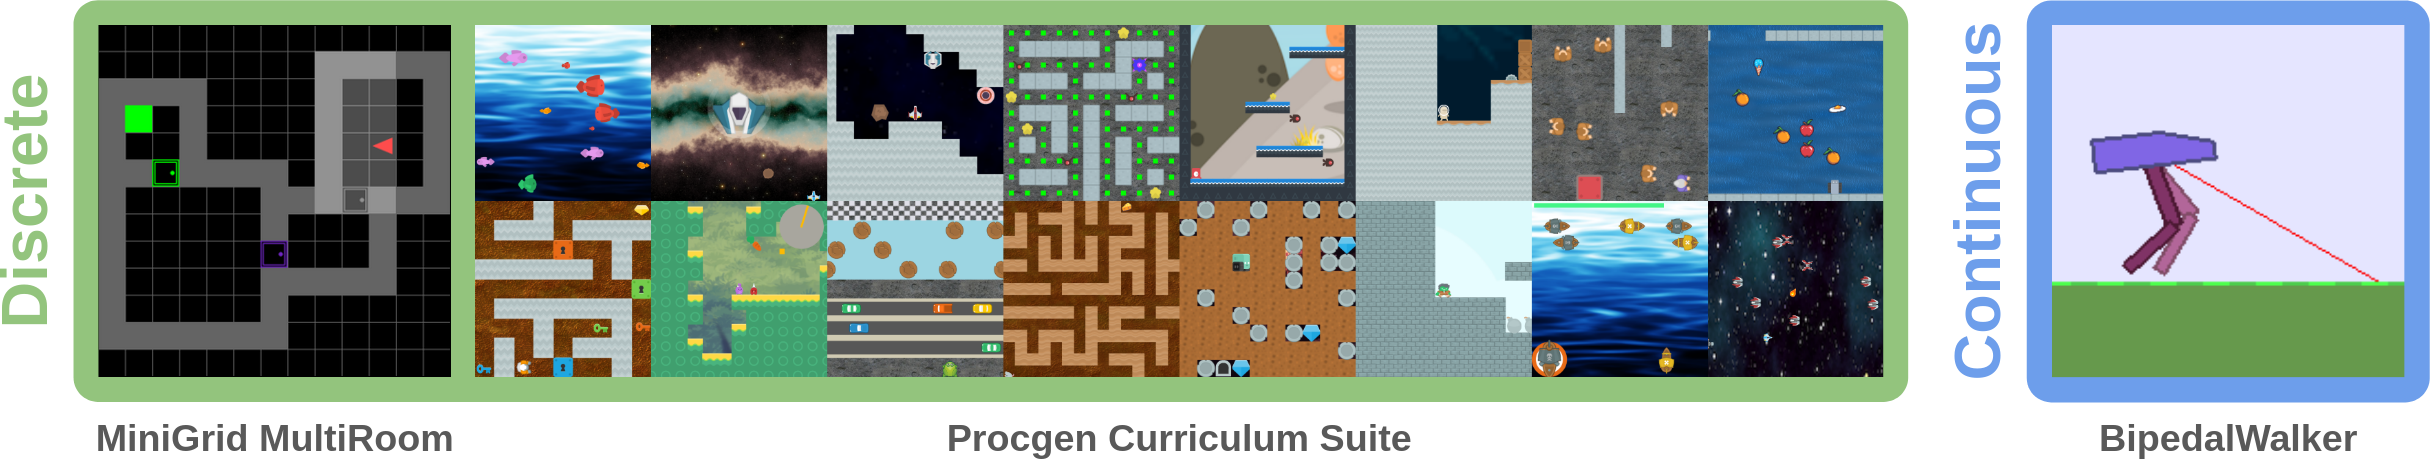 Transactions on Machine Learning Research (TMLR), Aug 2026
Cite this paper
@article{lee2026curate, title = {CURATE: Automatic Curriculum Learning for Reinforcement Learning Agents through Competence-Based Curriculum Policy Search in Structured Task Spaces}, author = {Lee, Tabitha Edith and Ke, Nan Rosemary and Patil, Sarvesh and Dahmani, Annya and Yiu, Eunice and Saleh, Esra'a and Gopnik, Alison and Kroemer, Oliver and Berseth, Glen}, journal = {Transactions on Machine Learning Research (TMLR)}, year = {2026}, month = aug, } -
 IEEE Robotics and Automation Letters, 2024
Cite this paper
@article{cheng2023enhancing,
  title = {Enhancing Dexterity in Robotic Manipulation via Hierarchical Contact Exploration},
  author = {Cheng, Xianyi and Patil, Sarvesh and Temel, Zeynep and Kroemer, Oliver and Mason, Matthew T.},
  journal = {IEEE Robotics and Automation Letters},
  year = {2024},
  volume = {9},
  number = {1},
  pages = {390--397},
}
60 citations · Google Scholar, Sep 13, 2026
-
 In IEEE International Conference on Robotics and Automation (ICRA), 2023
Cite this paper
@inproceedings{patil2022linear,
  title = {Linear Delta Arrays for Compliant Dexterous Distributed Manipulation},
  author = {Patil, Sarvesh and Tao, Tony and Hellebrekers, Tess and Kroemer, Oliver and Temel, F. Zeynep},
  booktitle = {IEEE International Conference on Robotics and Automation (ICRA)},
  year = {2023},
  pages = {10324--10330},
}
13 citations · Google Scholar, Sep 13, 2026
-
 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
Cite this paper
@inproceedings{Patil2022DeltaZAA,
  title = {DeltaZ: An Accessible Compliant Delta Robot Manipulator for Research and Education},
  author = {Patil, Sarvesh and Alvares, Samuel C. and Mannam, Pragna and Kroemer, Oliver and Temel, F. Zeynep},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year = {2022},
}
14 citations · Google Scholar, Sep 13, 2026


Beyond Research
I love travel, exploring new cultures, cuisines, plants, rocks, and sunsets!
- Visited
- Still to explore
- Visited
- Still to visit
The remaining eight: Hawaii, Vermont, Maine, Alabama, Mississippi, Alaska, Kansas, New Hampshire.
My national park checklist
- Arches
- Badlands
- Big Bend
- Black Canyon of the Gunnison
- Bryce Canyon
- Canyonlands
- Crater Lake
- Cuyahoga Valley
- Glacier
- Grand Canyon
- Grand Teton
- Great Sand Dunes
- Great Smoky Mountains
- Hot Springs
- Lassen Volcanic
- Mammoth Cave
- Mount Rainier
- New River Gorge
- North Cascades
- Olympic
- Redwood
- Rocky Mountain
- Shenandoah
- Theodore Roosevelt
- Wind Cave
- Yellowstone
- Yosemite
- Zion
Hover, tap, or focus on a highlighted place to explore.
Map inspiration: Liza Dahiya. Geography: Natural Earth
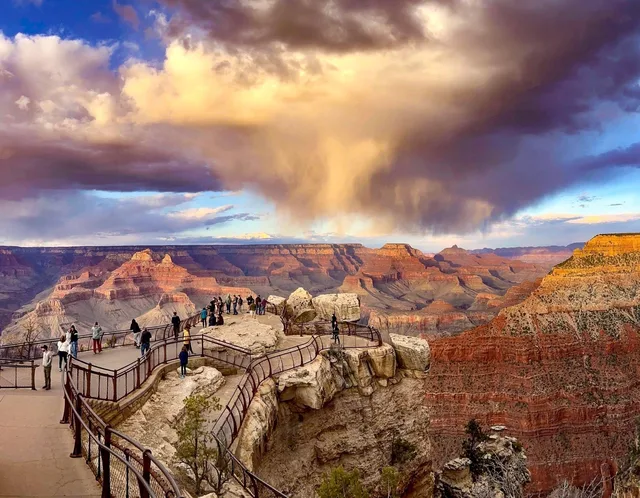 Photo unavailable
Grand Canyon
Sunset from Mather Point
NPS/M. Quinn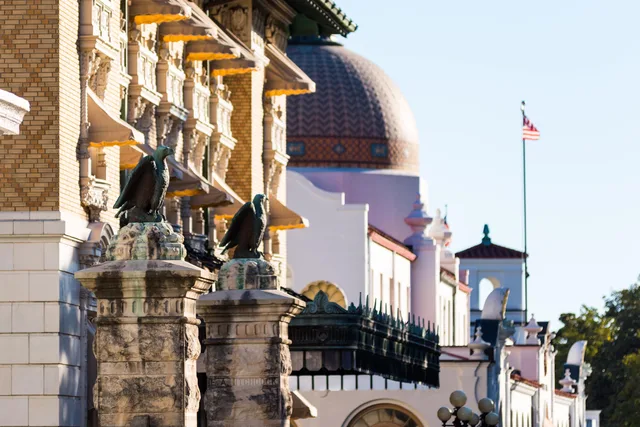 Photo unavailable
Hot Springs
Bathhouse Row
NPS photo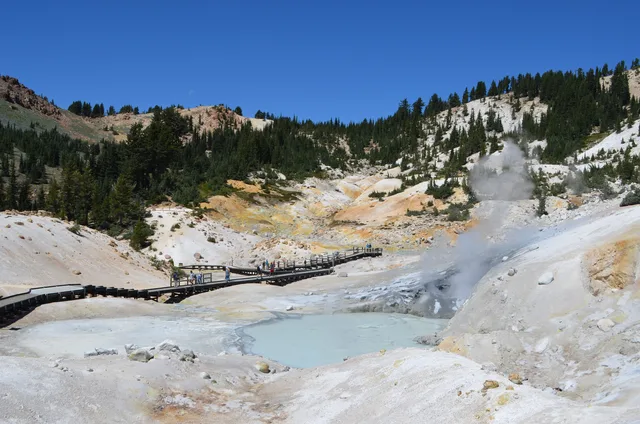 Photo unavailable
Lassen Volcanic
Bumpass Hell
NPS Photo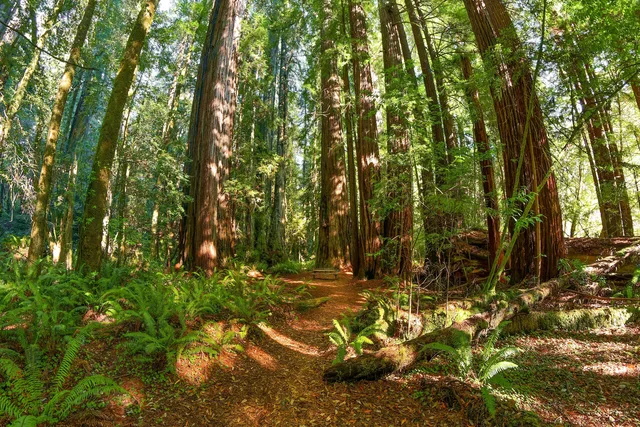 Photo unavailable
Redwood
A Redwood Grove
NPS / Steve Olson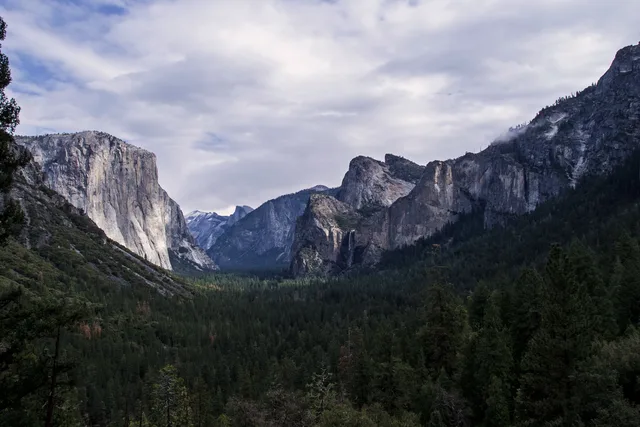 Photo unavailable
Yosemite
Yosemite Valley from Tunnel View
NPS / Cindy Jacoby Photo unavailable
Black Canyon of the Gunnison
Black Canyon near Painted Wall
NPS Photo/Lynch Photo unavailable
Great Sand Dunes
Dunes and Crestone Peaks at Sunset
NPS/Patrick Myers Photo unavailable
Rocky Mountain
Bear Lake
NPS Photo Photo unavailable
Yellowstone
Grand Prismatic Spring
NPS/Jim Peaco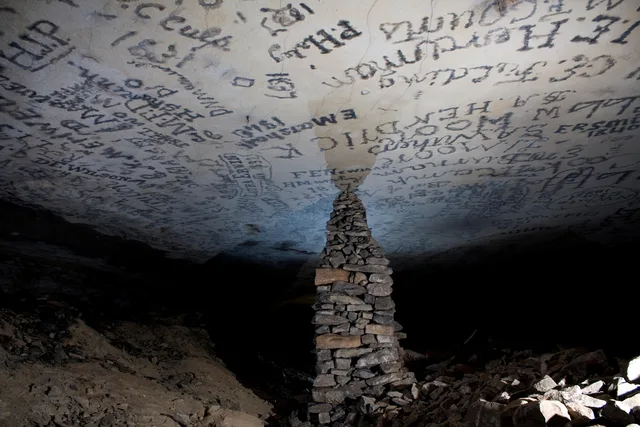 Photo unavailable
Mammoth Cave
Gothic Avenue
NPS Photo/ Jackie Wheet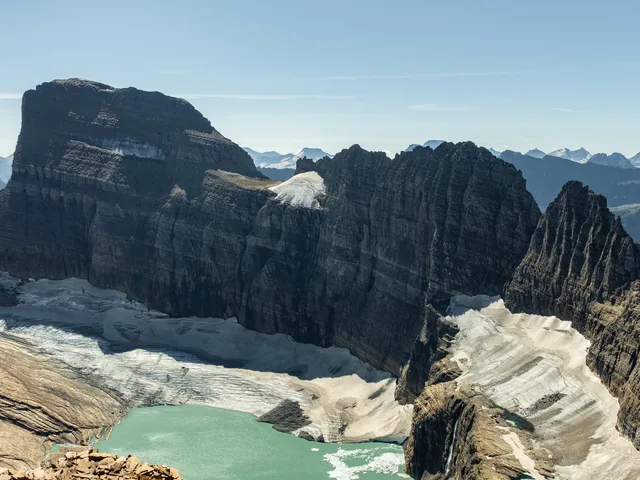 Photo unavailable
Glacier
Grinnell Glacier from Upper Grinnell Ridge in 2021
NPS Photo Photo unavailable Yellowstone
Grand Prismatic Spring
NPS/Jim Peaco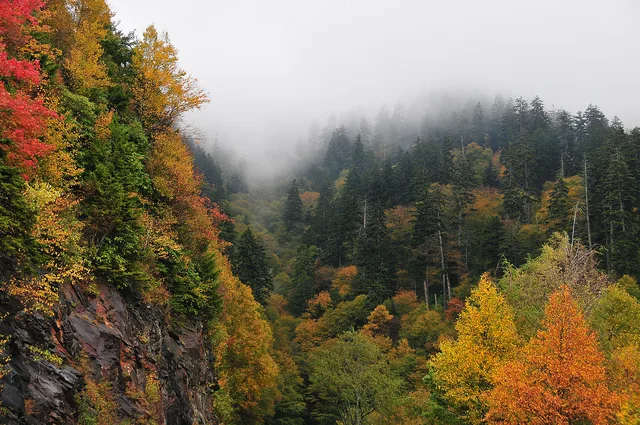 Photo unavailable
Great Smoky Mountains
Fall Colors Near Newfound Gap
NPS Photo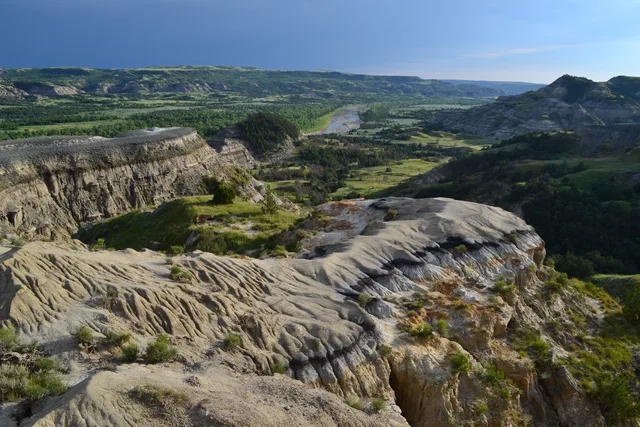 Photo unavailable
Theodore Roosevelt
River Bend Overlook, North Unit
NPS Photo / Mark Meyers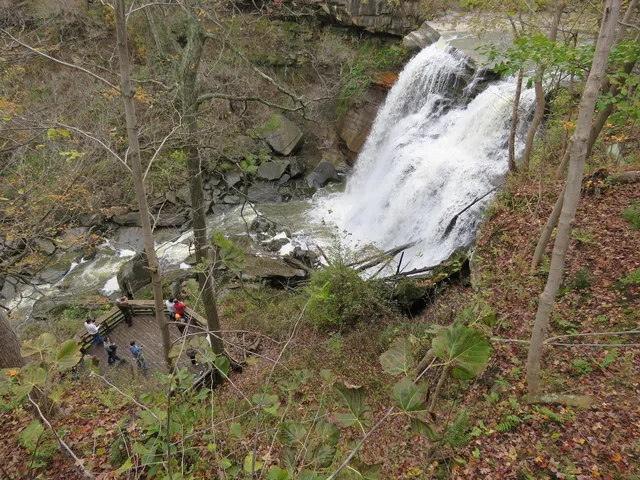 Photo unavailable
Cuyahoga Valley
Brandywine Falls Viewed from the Upper Boardwalk
NPS Photo / D.J. Reiser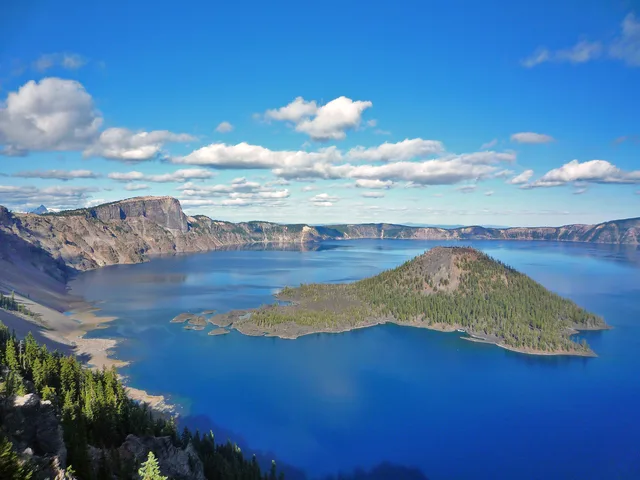 Photo unavailable
Crater Lake
Wizard Island
NPS Photo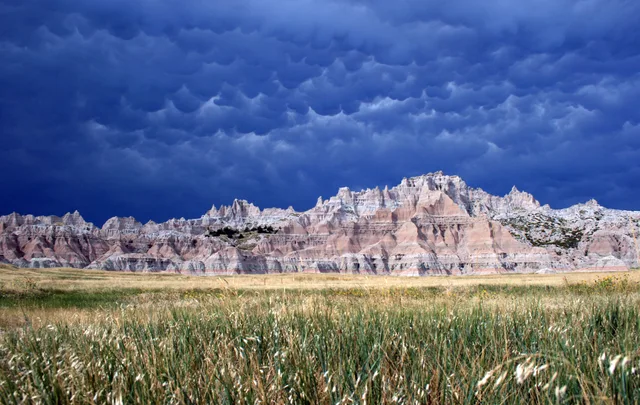 Photo unavailable
Badlands
Badlands Storm
NPS Photo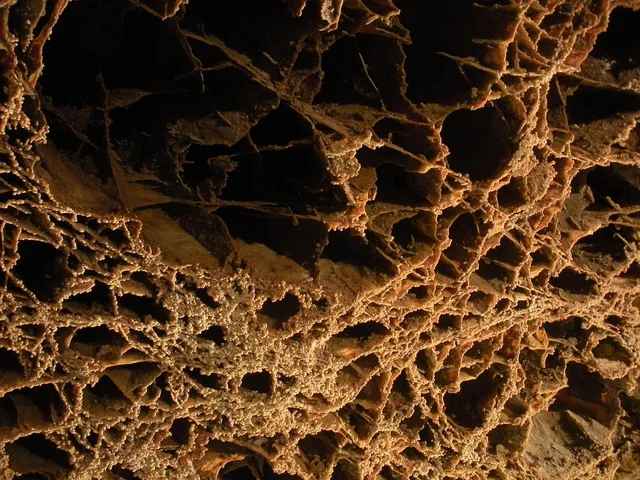 Photo unavailable
Wind Cave
Boxwork in the Elk's Room
NPS Photo Photo unavailable Great Smoky Mountains
Fall Colors Near Newfound Gap
NPS Photo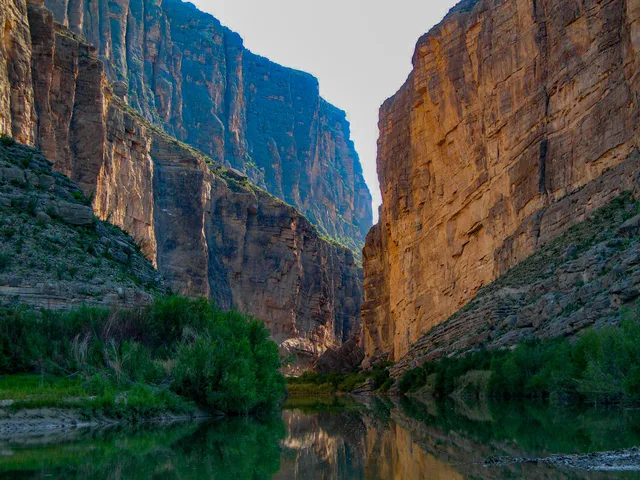 Photo unavailable
Big Bend
Santa Elena Canyon
NPS / B. Trester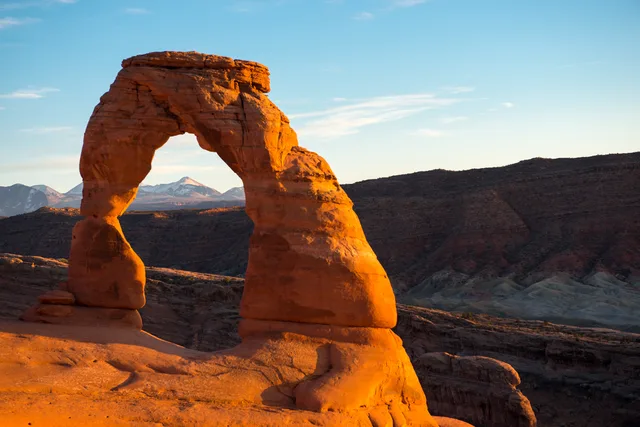 Photo unavailable
Arches
Delicate Arch
NPS Photo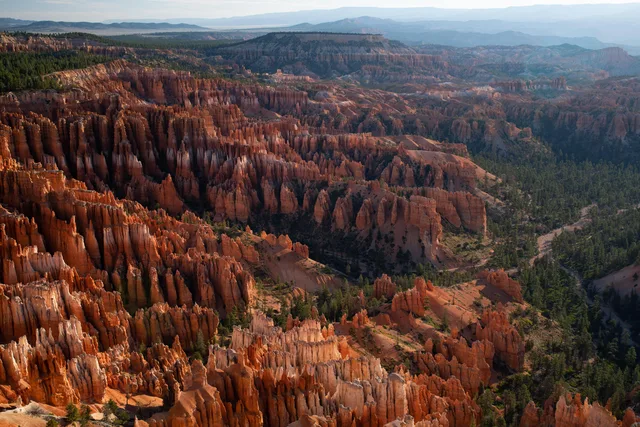 Photo unavailable
Bryce Canyon
Bryce Amphitheater from Inspiration Point
NPS Photo / Peter Densmore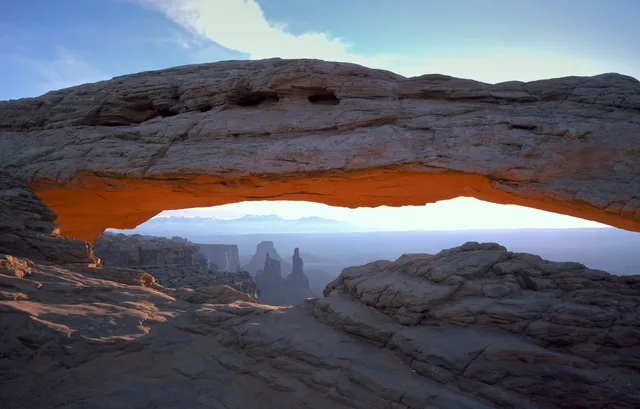 Photo unavailable
Canyonlands
Mesa Arch
NPS/Neal Herbert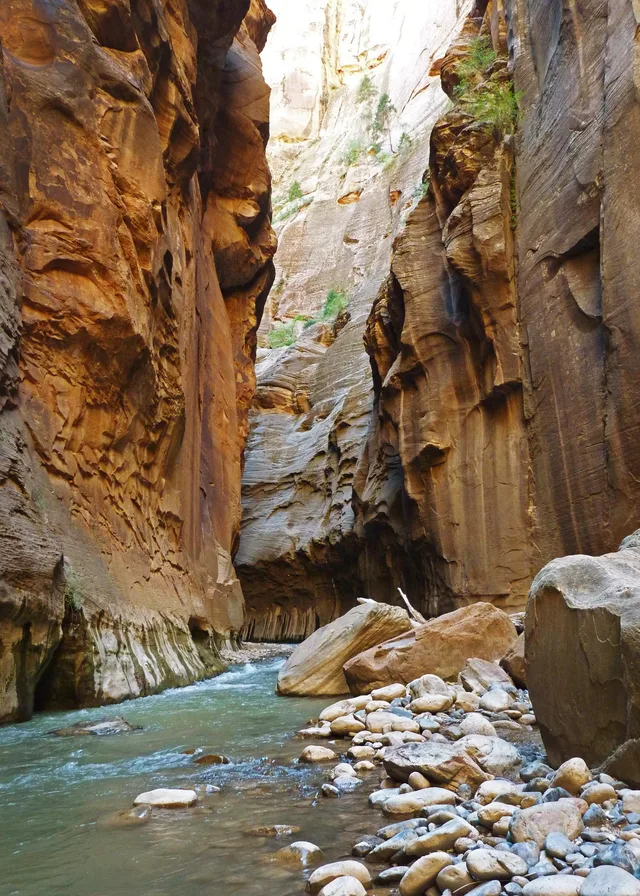 Photo unavailable
Zion
The Narrows
NPS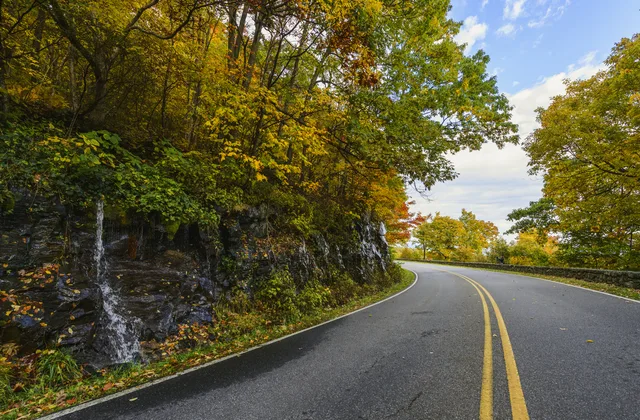 Photo unavailable
Shenandoah
Driving on Skyline Drive
NPS Photo / Neal Lewis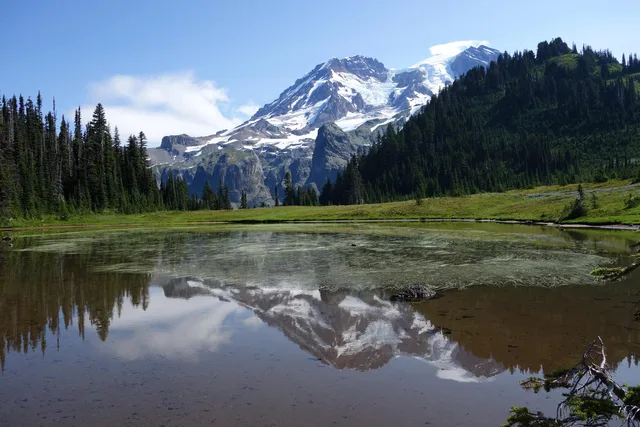 Photo unavailable
Mount Rainier
Mount Rainier from Aurora Lake
NPS Photo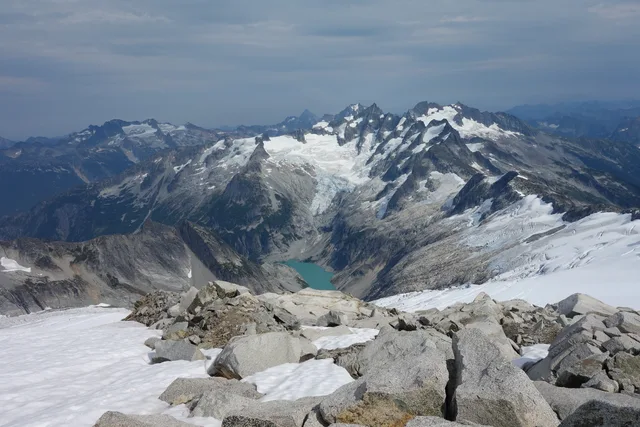 Photo unavailable
North Cascades
Jagged Mountain Peaks
NPS Photo/T. Baldwin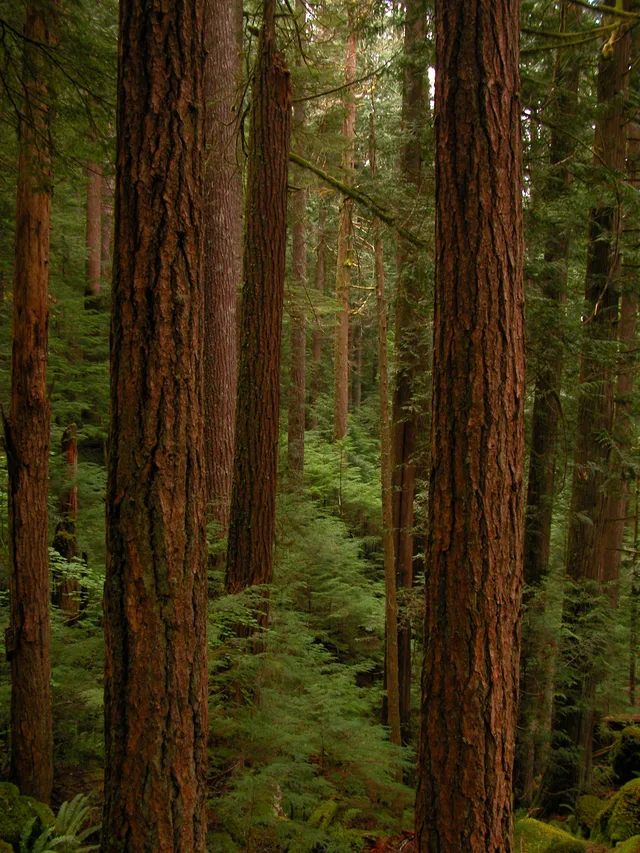 Photo unavailable
Olympic
Olympic Forest
NPS Photo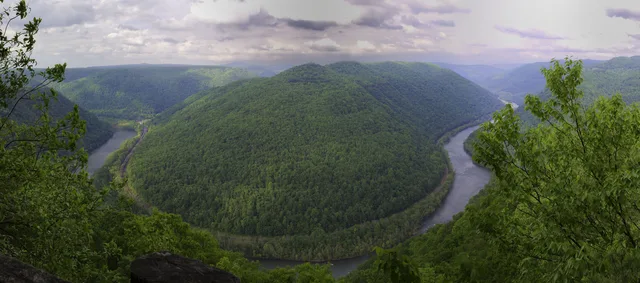 Photo unavailable
New River Gorge
Horseshoe Bend from Grandview
NPS photo/Louise McLaughlin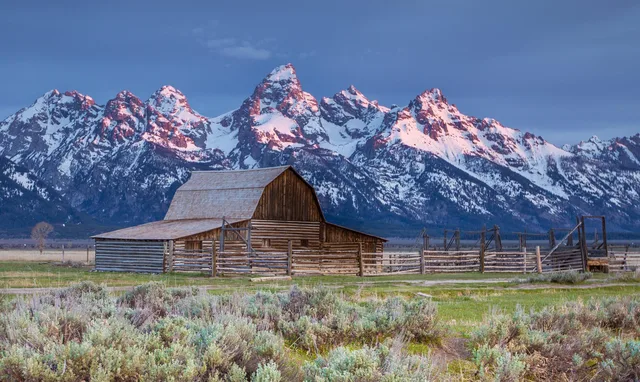 Photo unavailable
Grand Teton
Moulton Barn
NPS Photo/Tobiason Photo unavailable Yellowstone
Grand Prismatic Spring
NPS/Jim Peaco