Publications
Journal articles, conference papers, and full preprints. See also Google Scholar.
2026
-
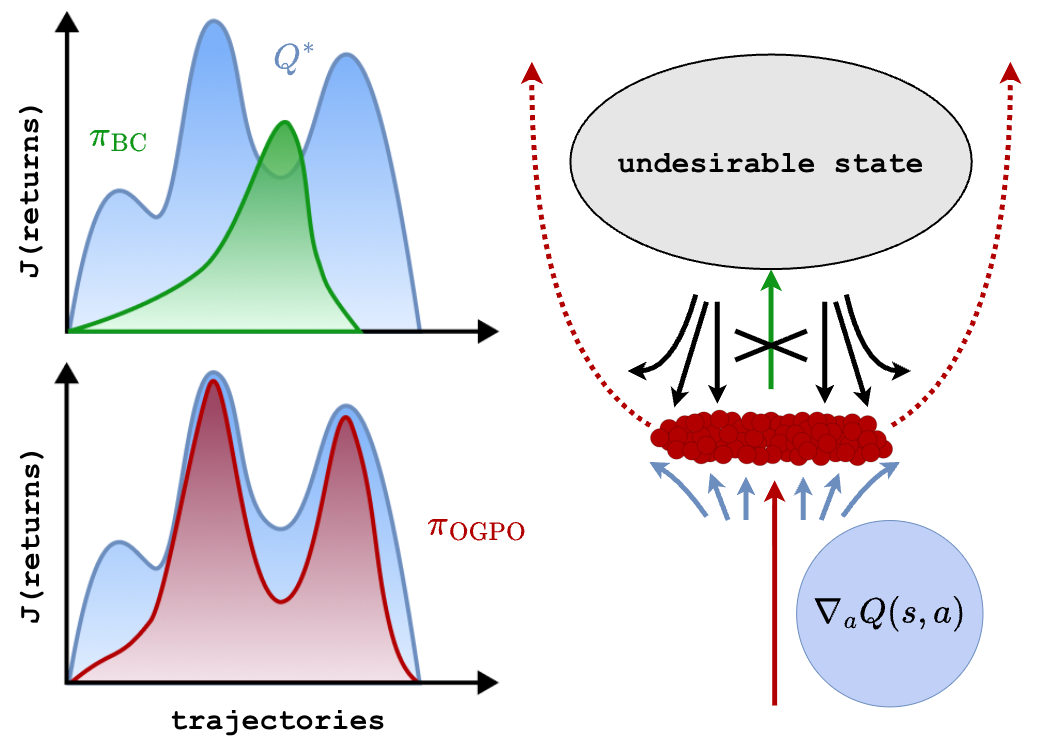 In International Conference on Machine Learning (ICML), 2026
Cite this paper
@inproceedings{patil2026ogpo, title = {OGPO: Sample Efficient Full-Finetuning of Generative Control Policies}, author = {Patil, Sarvesh and Nakamoto, Mitsuhiko and Agarwal, Manan and Saxena, Shashwat and Zhang, Jesse and Anantharaman, Giri and Winston, Cleah and Pan, Chaoyi and Chen, Douglas and Huang, Nai-Chieh and Temel, Zeynep and Kroemer, Oliver and Levine, Sergey and Gupta, Abhishek and Dai, Hongkai and Shah, Paarth and Simchowitz, Max}, booktitle = {International Conference on Machine Learning (ICML)}, year = {2026}, } -
 arXiv preprint arXiv:2609.06930, 2026
Cite this paper
@article{Patil2025MADDM, title = {Distributed Dexterous Manipulation with Spatially Conditioned Multi-Agent Transformers}, author = {Patil, Sarvesh}, journal = {arXiv preprint arXiv:2609.06930}, year = {2026}, } -
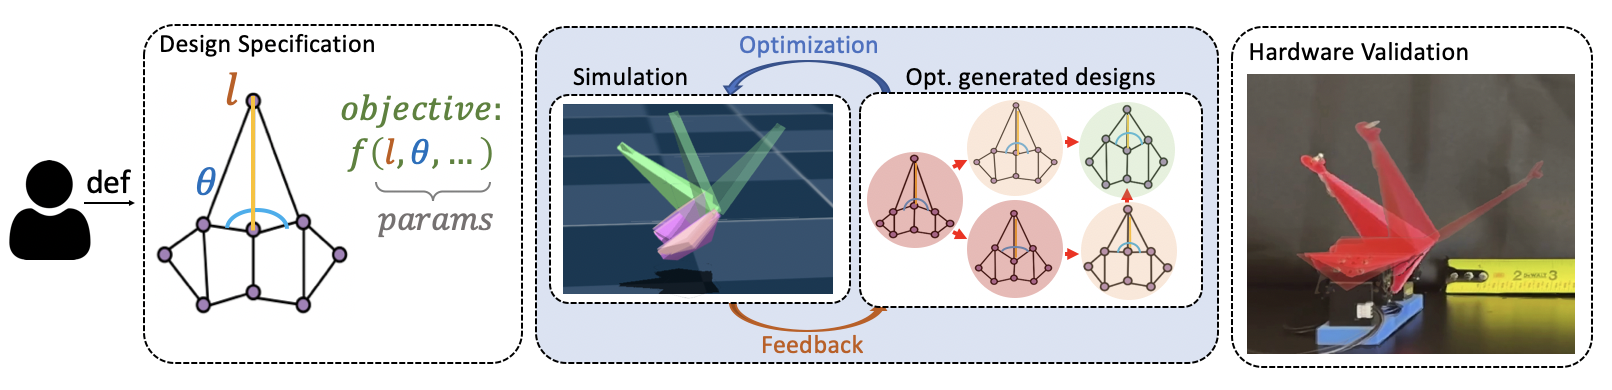 In IEEE International Conference on Soft Robotics (RoboSoft), 2026
Cite this paper
@inproceedings{han2026fold, title = {From Fold to Function: Simulation-Driven Design of Origami Mechanisms}, author = {Han, Tianhui and Singh, Shashwat and Patil, Sarvesh and Temel, Zeynep}, booktitle = {IEEE International Conference on Soft Robotics (RoboSoft)}, pages = {843--850}, year = {2026}, } -
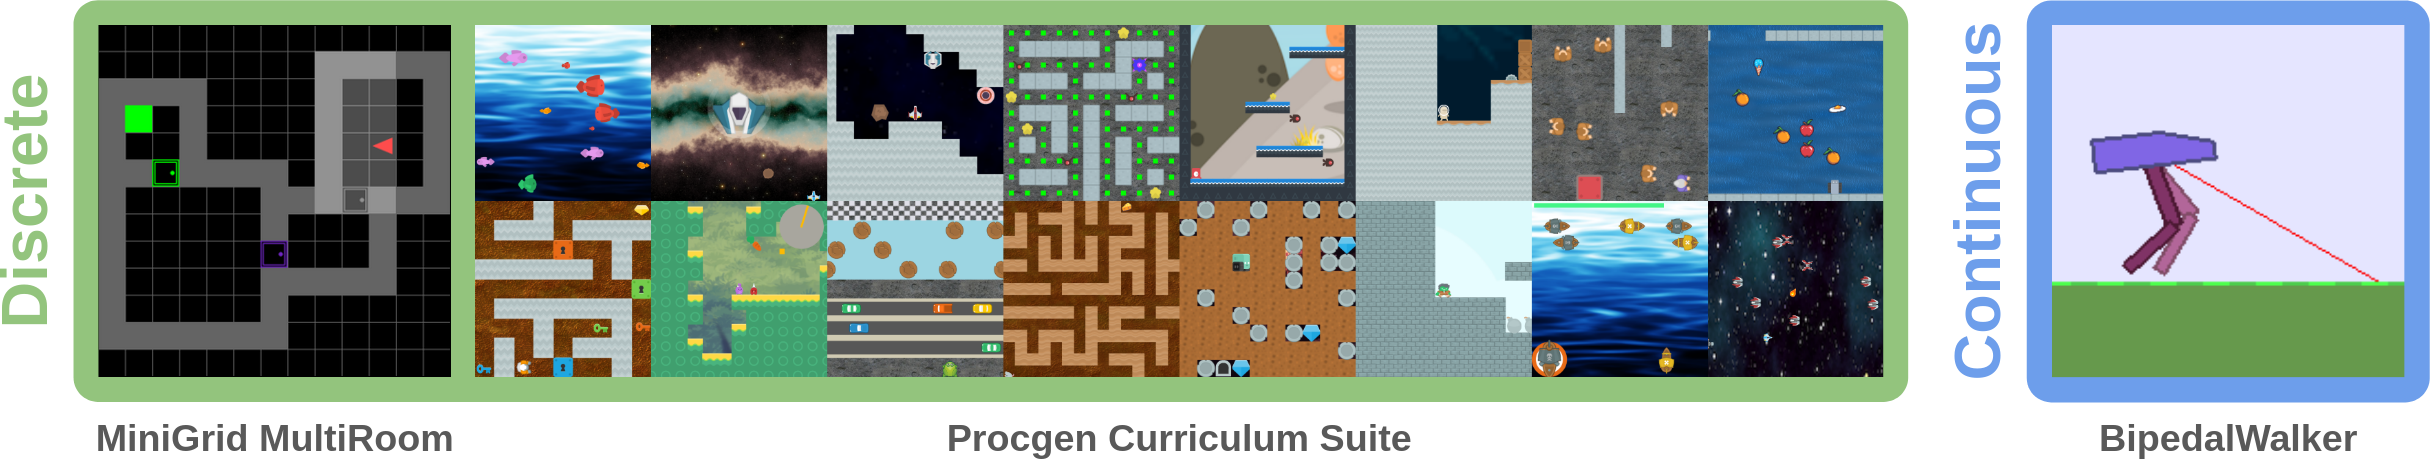 Transactions on Machine Learning Research (TMLR), Aug 2026
Cite this paper
@article{lee2026curate,
  title = {CURATE: Automatic Curriculum Learning for Reinforcement Learning Agents through Competence-Based Curriculum Policy Search in Structured Task Spaces},
  author = {Lee, Tabitha Edith and Ke, Nan Rosemary and Patil, Sarvesh and Dahmani, Annya and Yiu, Eunice and Saleh, Esra'a and Gopnik, Alison and Kroemer, Oliver and Berseth, Glen},
  journal = {Transactions on Machine Learning Research (TMLR)},
  year = {2026},
  month = aug,
}


2024
-
 IEEE Robotics and Automation Letters, 2024
Cite this paper
@article{cheng2023enhancing,
  title = {Enhancing Dexterity in Robotic Manipulation via Hierarchical Contact Exploration},
  author = {Cheng, Xianyi and Patil, Sarvesh and Temel, Zeynep and Kroemer, Oliver and Mason, Matthew T.},
  journal = {IEEE Robotics and Automation Letters},
  year = {2024},
  volume = {9},
  number = {1},
  pages = {390--397},
}
60 citations · Google Scholar, Sep 13, 2026
2023
-
 In IEEE International Conference on Robotics and Automation (ICRA), 2023
Cite this paper
@inproceedings{patil2022linear,
  title = {Linear Delta Arrays for Compliant Dexterous Distributed Manipulation},
  author = {Patil, Sarvesh and Tao, Tony and Hellebrekers, Tess and Kroemer, Oliver and Temel, F. Zeynep},
  booktitle = {IEEE International Conference on Robotics and Automation (ICRA)},
  year = {2023},
  pages = {10324--10330},
}
13 citations · Google Scholar, Sep 13, 2026

2022
-
 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
Cite this paper
@inproceedings{Patil2022DeltaZAA,
  title = {DeltaZ: An Accessible Compliant Delta Robot Manipulator for Research and Education},
  author = {Patil, Sarvesh and Alvares, Samuel C. and Mannam, Pragna and Kroemer, Oliver and Temel, F. Zeynep},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year = {2022},
}
14 citations · Google Scholar, Sep 13, 2026

2020
-
 arXiv preprint arXiv:2010.09594, 2020
Cite this paper
@article{Patil2020MultiModalSR,
  title = {Multi-Modal Super Resolution for Dense Microscopic Particle Size Estimation},
  author = {Patil, Sarvesh and Rajanish, Chava Y P D Phani and Margankunte, Naveen},
  journal = {arXiv preprint arXiv:2010.09594},
  year = {2020},
}
5 citations · Google Scholar, Sep 13, 2026

2018
- arXivarXiv preprint arXiv:1808.04459, 2018
Cite this paper
@article{patil2018speech,
  title = {Deep Learning Based Natural Language Processing for End to End Speech Translation},
  author = {Patil, Sarvesh},
  journal = {arXiv preprint arXiv:1808.04459},
  year = {2018},
}
3 citations · Google Scholar, Sep 13, 2026
-
 Use of UAVs for mining applicationsInternational Journal of Advance Research, Ideas and Innovations in Technology, 2018
Cite this paper
@article{Patil2018UseOU,
  title = {Use of UAVs for mining applications},
  author = {Patil, Sarvesh and Patil, Atharva and Nair, Nikhil and Nair, Midhun and Tawde, Gaurav},
  journal = {International Journal of Advance Research, Ideas and Innovations in Technology},
  year = {2018},
  volume = {4},
  number = {2},
  pages = {2691--2696},
}
2 citations · Google Scholar, Sep 13, 2026
